TRAIN · NEWS FROM THE INDUSTRY
A robot score needs its test conditions
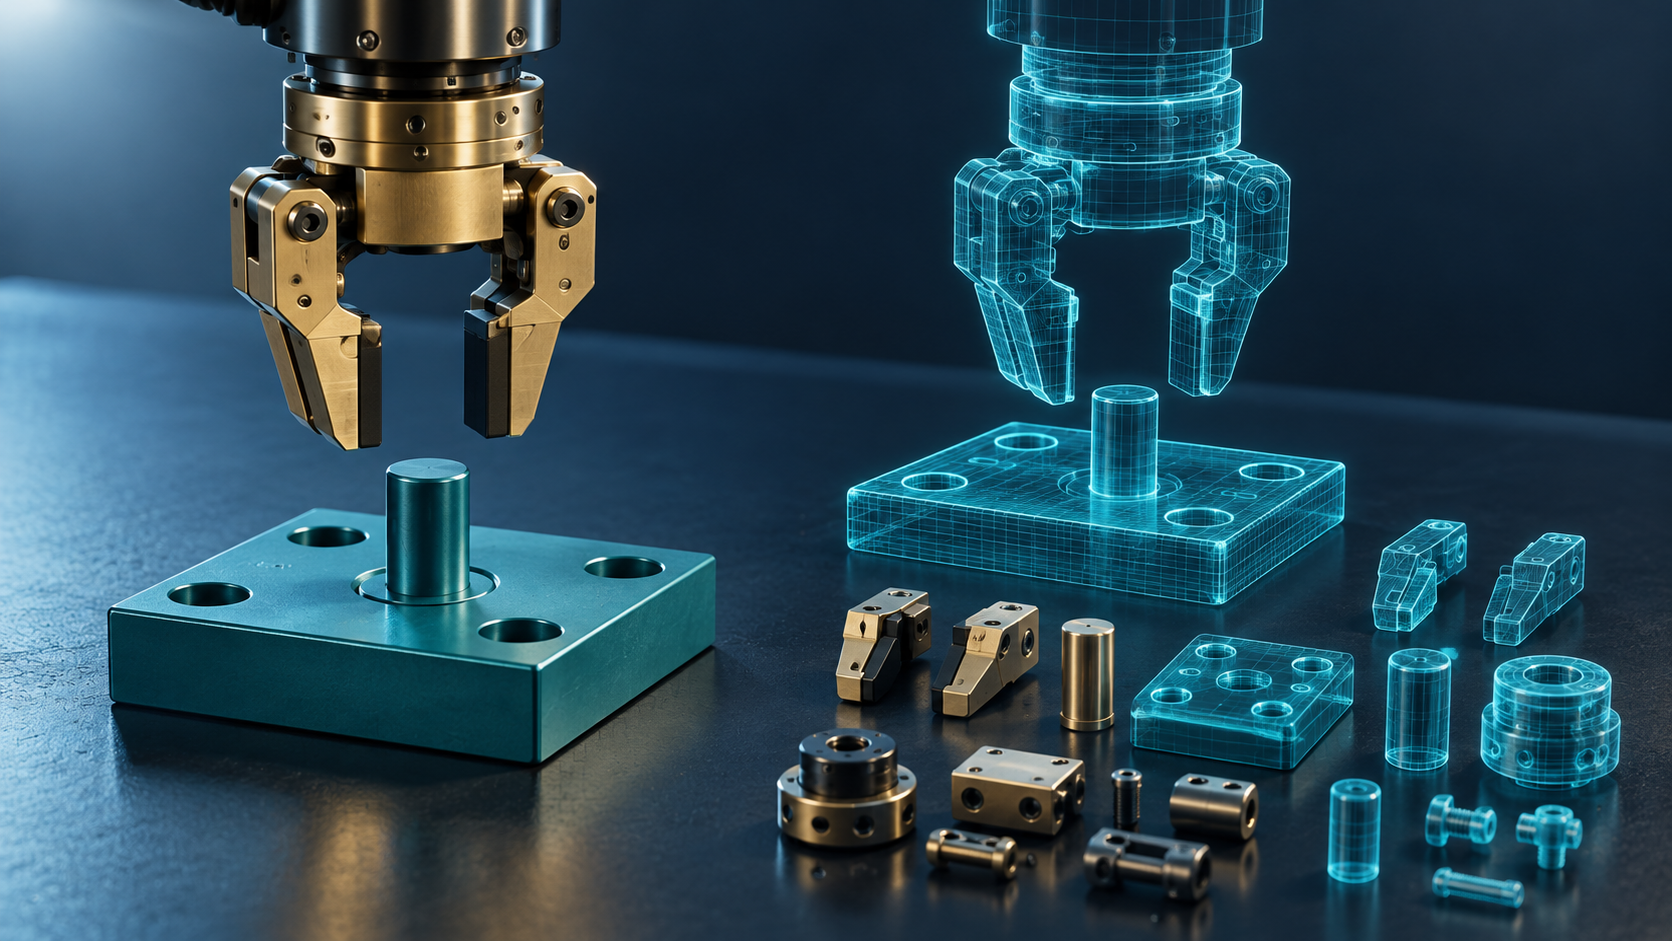
ProjectSim’s September benchmarking overview argues that robot evaluations should identify what a policy needs to practise next, rather than compress every ability into one score. Its own first experiment investigates whether more faithful simulated assets and scenes bring policy performance closer to a physical setup. The practical point is to preserve the difficulty being tested: if a simulated insertion removes the contact problem that defeats a real robot, more successful virtual practice may teach the wrong lesson.
Why it’s useful. This is a useful lens for synthetic-data and scenario design. Track the failure condition, document geometry and physical properties, and compare targeted practice with an equal amount of general practice.
What to keep in mind. ProjectSim describes a research direction, not a demonstrated solution to the real-to-sim gap. This edition does not independently verify the benchmark results reviewed in its article or claim its planned experiment has succeeded.
- Robotics benchmarking: where we are, and what comes next ProjectSim · Source published
In Practice, then prove it · Coverage –